
SEPTEMBER 27 - OCTOBER 1, 2026 | PITTSBURGH, PA, USA
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is one of the largest and most impactful robotics research conferences worldwide.
IROS 2026 will bring together researchers, engineers, and industry leaders in Pittsburgh, a city at the forefront of robotics innovation, home to world-renowned institutions and cutting-edge autonomous vehicle companies.
Monday September 28th Schedule at a Glance
| Time | Session Title & Location | Paper Title | Authors | Poster Session Time & Location |
| 9:09am | Reinforcement Learning for Agile Humanoid and Legged Locomotion | LT#4125Room 315/316 | AGILE: A Comprehensive Workflow for Humanoid Loco-Manipulation Learning | Zhao, Huihua; Cathomen, Rafael; Gulich, Lionel; Liu, Wei; Ongan, Efe; Lin, Michael A.; Jain, Shalin; Pouya, Soha; Chang, Yan | Sep. 28 | 11am - 12:30pm | Kiosk B11 #4125 |
| 9:22am | Legged Locomotion Over Difficult Ground | FO#4Room 334 | Probabilistic Approach to Feedback Control Enhances Multi-Legged Locomotion on Rugged Landscapes | He, Juntao; Chong, Baxi; Lin, Jianfeng; Xu, Zhaochen James; Bagheri, Hosain; Flores, Esteban; Goldman, Daniel | Sep. 28 | 11am - 12:30pm | KioskA2 #4 |
| 9:57am | Snake and Modular Robot Locomotion | FO#3275Room 335 | Vertical Mobility and RL-Based Locomotion of a Snake-Like Robot for Building Foundation Inspection | Paton, Michael; Alindogan, Jedidiah; Shigeto, Shuhei; Rieber, Richard; Cho, Joshua; Lee, HoJun; Lee, Joohyuk; Swan, Michael; Carpenter, Kalind; Fernandez, Matthew; Abdhul Rahuman, Mohomad Aqeel; Lathr | Sep. 28 | 11am - 12:30pm | Kiosk B3 #3275 |
| 10:09am | Modeling Motion and Environment for Navigation | LT#3565 Room 317/318 | StratMamba: Strategic and Reactive Stream Partitioning for Path-Efficient LiDAR-Based Obstacle Avoidance | Wu, Hung-Chieh; Zhang, Xiaopan; Sinaei, Kasra; Abnavi, Ryan; Kulathun Mudiyanselage, Kasun Weerakoon; Bradley, Christopher; Fakoorian, Seyed Abolfazl; Li, Jiachen; Ebeigbe, Donald | Sep. 28 | 11am - 12:30pm | Exhibit Hall B #3565 |
| 10:18am | Extending Vision-Language-Action Model Capabilities | LT#3972Room 401/402 | OG-VLA: Orthographic Image Generation for 3D-Aware Vision-Language Action Model | Singh, Ishika; Goyal, Ankit; Birchfield, Stan; Fox, Dieter; Garg, Animesh; Blukis, Valts | Sep. 28 | 11am - 12:30pm | Kiosk E3 #3972 |
| 11am - 12:30pm | Demo Session | Rm 304/305 | #4052 | Unifying Sidewinding and Rolling: A Wave-Based Framework for Self-Righting in Elongated Limbless and Multi-Legged Robots | Liu, Hangjun; Geng, Jiarui; Ding, Jinxuan; He, Gengzhi; Wang, Xiyuan; Arukgoda, Melisa Oshaini; DiGennaro, Joseph; George, Ubertalli; Blekherman, Grigoriy; Chong, Baxi | |
| 2:52pm | Whole-Body Control for Novel Robot Behaviors | FO#2823Room 320 | Whole-Body Model Predictive Control for Spin-Aware Quadrupedal Table Tennis | Nguyen, David; Zaidi, Zulfiqar; Karol, Kevin; Hodgins, Jessica; Xie, Zhaoming | Sep. 28 | 4:30pm - 6pm | Exhibit Hall B #2823 |
| 3:05pm | Finding Better Representations for Imitation Learning | LT#3032Room 302/303 | KEYGEN: Unsupervised Keypoint Based Object-Centric Representations for Category-Level Policy Generalization | Cao, Shuxin; Wang, Liquan; Moghani, Masoud; Joffe, Benjamin; Garg, Animesh | Sep. 28 | 4:30pm - 6pm | Exhibit Hall B #3032 |
| 3:11pm | Ensuring Safety in Robot Motion and Control | LT#5020Room 411/412 | PolyMerge: Compressing 3D Gaussian Splats with Polytope Coverings for Provably Safe Resource-Constrained Navigation | Hong, Jihoon; Chiu, Chih-Yuan; Fridovich-Keil, Sara; Chou, Glen | Sep. 28 | 4:30pm - 6pm | Exhibit Hall B #5020 |
| 3:21pm | Task Allocation and Planning for Heterogeneous Teams | LT#3870 Room 315/316 | Scale-Plan: Scalable Language-Enabled Task Planning for Heterogeneous Multi-Robot Teams | Gupta, Piyush; Bae, Sangjae; Li, Jiachen; Isele, David | Sep. 28 | 4:30pm - 6pm | Exhibit Hall B #3870 |
| 3:34pm | Visual Place Recognition Through Novel Sensing | LT#4128 Room 317/318 | Localization for High-Speed Athletic Wheelchairs Using Line Semantics | Wu, Zixuan; Xiao, Qingyu; Tak, Ajay; Lee, Kin Man; Sreeramdass, Varshith; Barnes, Dylan; Lange, Kiersten; Tanwar, Sanchit; Gombolay, Matthew | Sep. 28 | 4:30pm - 6pm | Exhibit Hall B #4128 |
Monday Highlights
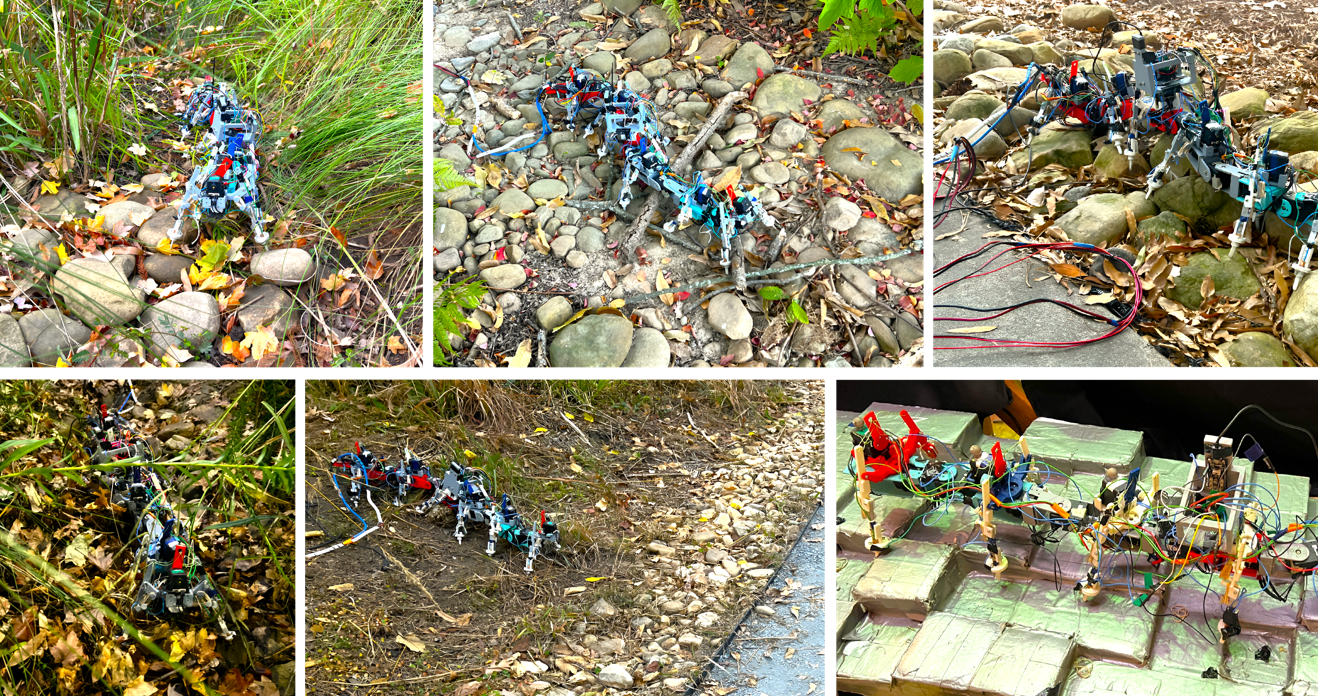
Probabilistic Approach to Feedback Control Enhances Multi-Legged Locomotion on Rugged Landscapes
Here, in laboratory and field experiments we demonstrate that a vertical body undulation wave helps to mitigate environmental disturbances affecting robot speed; these observations are supported by a probabilistic model. Using such insights, we introduce a control framework which monitors foot-ground contact patterns on rugose landscapes using binary foot-ground contact sensors to estimate terrain rugosity.
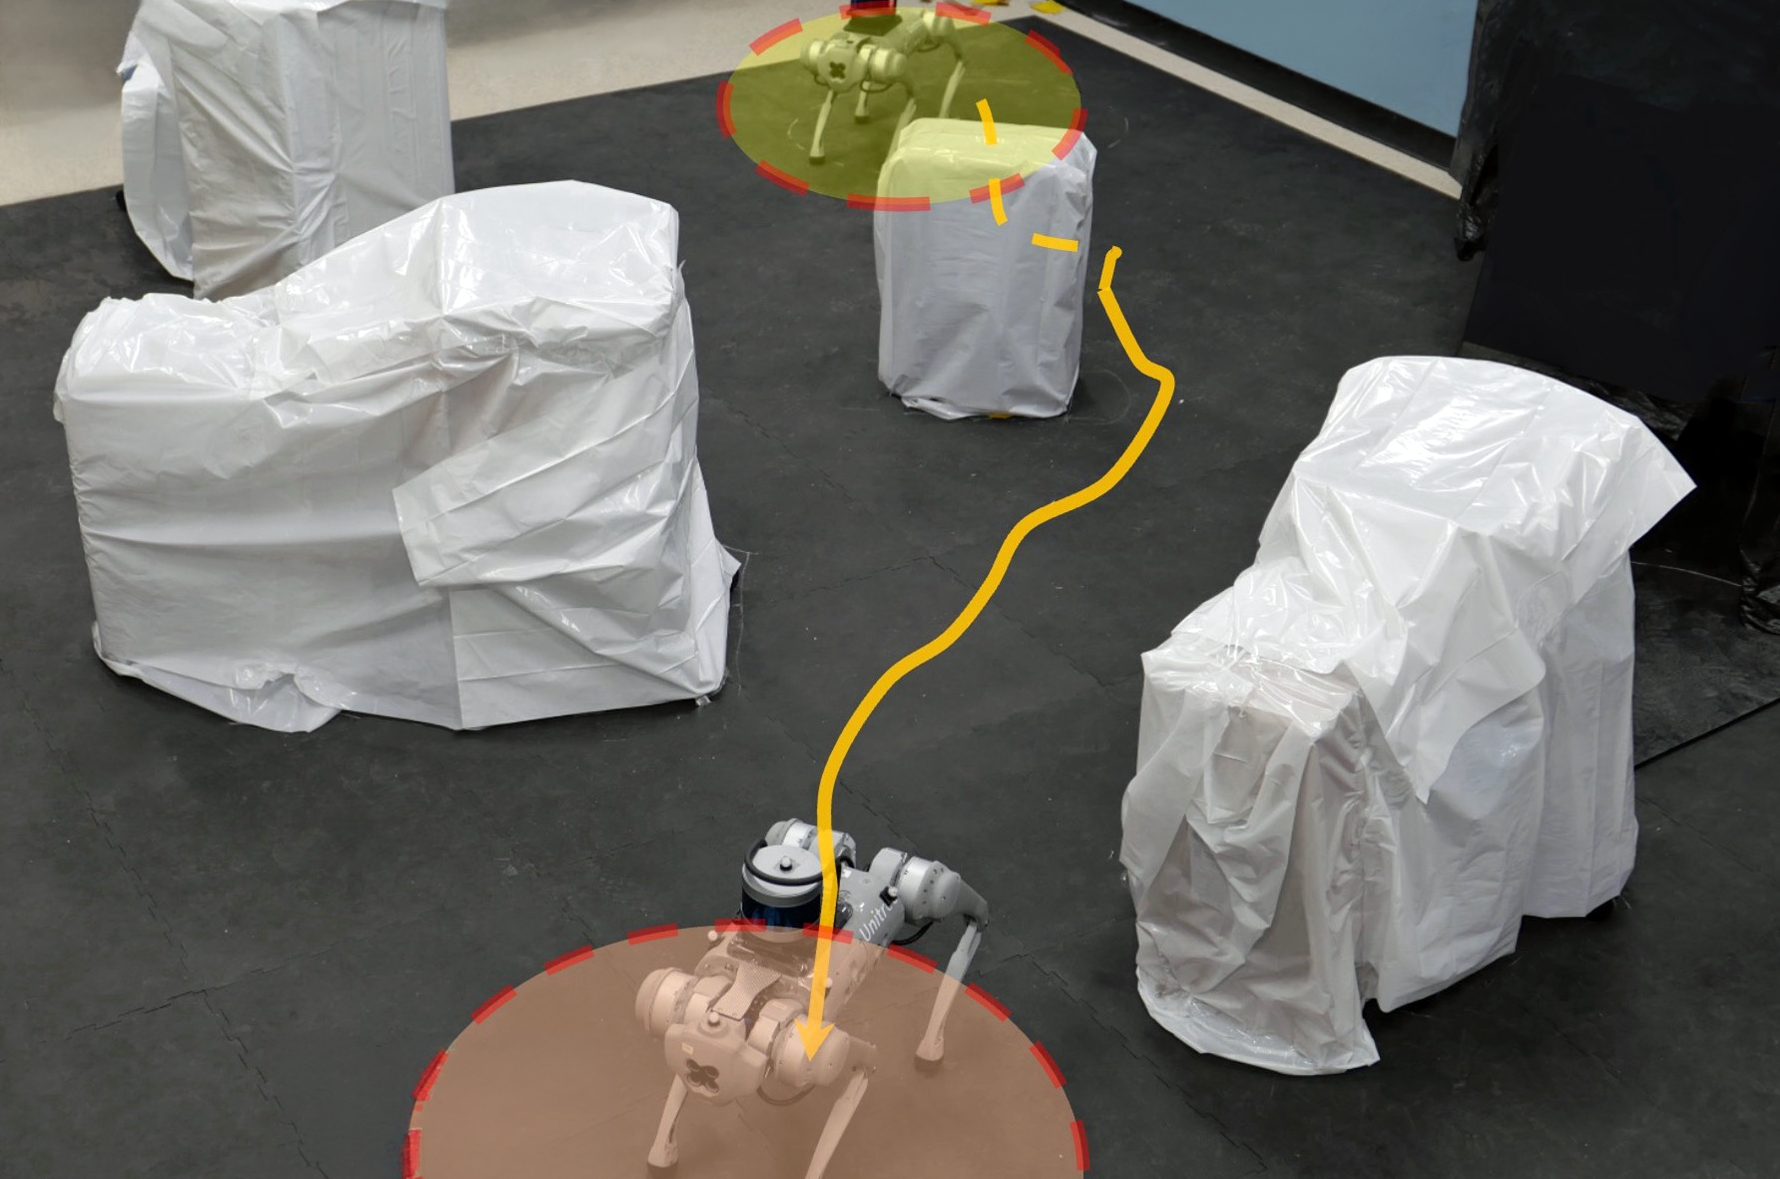
StratMamba: Strategic and Reactive Stream Partitioning for Path-Efficient LiDAR-Based Obstacle Avoidance
StratMamba leverages a combination of fast-decay and slow-decay memory architectures, where the fast-decay component processes high-frequency LiDAR data for reactive obstacle avoidance, while the slow-decay component maintains longer-horizon goal information for strategic planning.
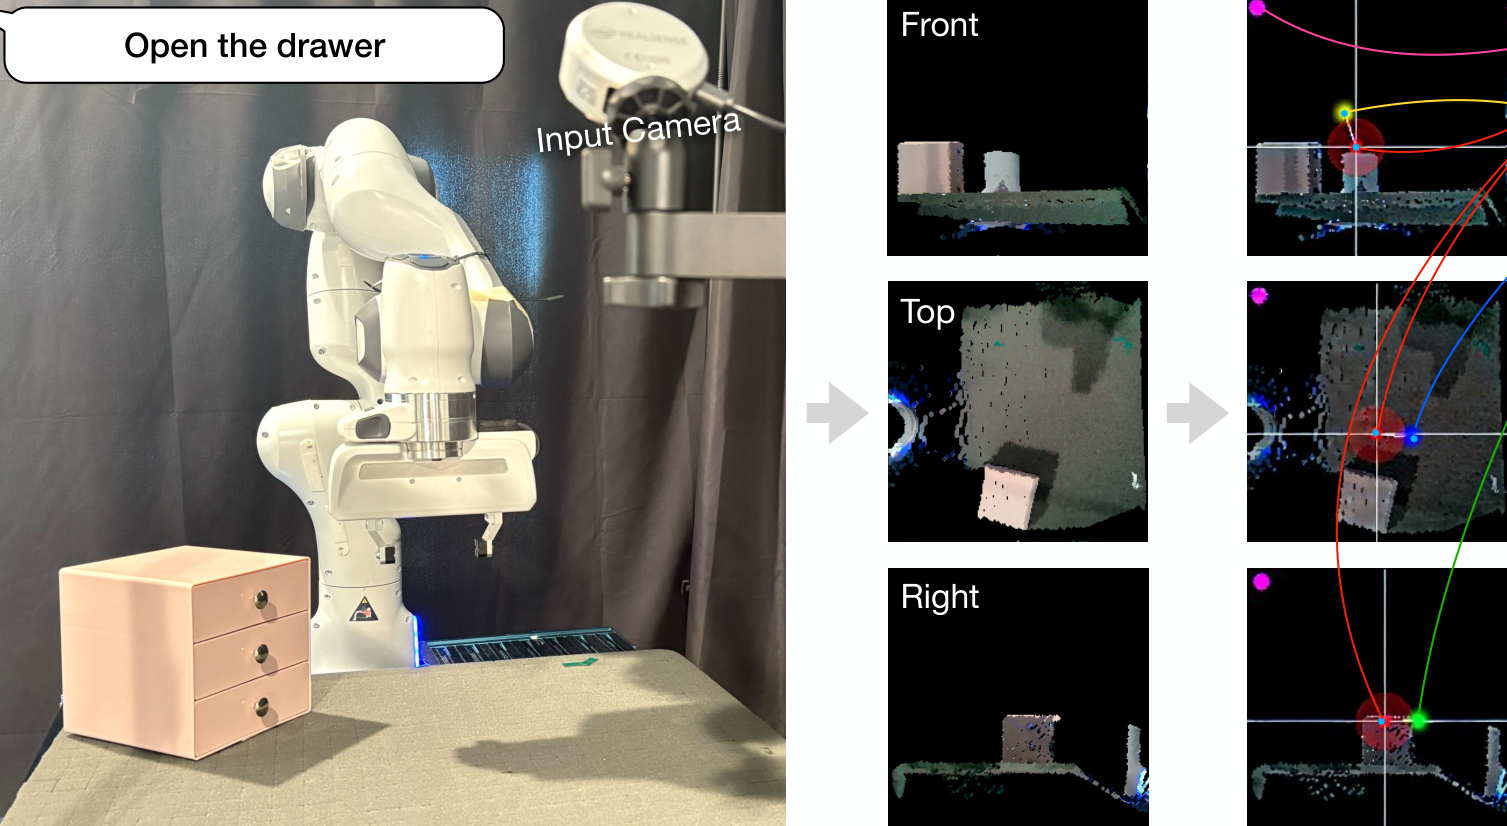
OG-VLA: Orthographic Image Generation for 3D-Aware Vision-Language Action Model
We introduce OG-VLA, a novel architecture and learning framework that combines the generalization strengths of Vision Language Action models (VLAs) with the robustness of 3D-aware policies.
Tuesday September 29th Schedule at a Glance
| Time | Session Title & Location | Title | Authors | Poster Session Time & Location |
| 9am - 9:11am | Control and Sensing for Legged Loco-Manipulation | FO#2729Room 334 | ACLM: ADMM-Based Distributed Model Predictive Control for Collaborative Loco-Manipulation | Zhou, Ziyi; Shu, Pengyuan; Cao, Ruize; Zhao, Yuntian; Zhao, Ye | Sep. 29 | 11am - 12:30pm | Exhibit Hall B #2729 |
| 9:07am | Efficient and Continual Learning of Robot Skills | LT Room 317/318 | Dynamic Policy Learning for Legged Robot with Simplified Model Pretraining and Model-Homotopy-Inspired Transfer | Kang, Dongyun; Kim, Min-Gyu; Song, Tae-Gyu; Kim, Hajun; Ha, Sehoon; Park, Hae-Won | Sep. 29 | 11am - 12:30pm | Exhibit Hall B #5030 |
| 10:07am | Model-Based Safety for Bipedal Walking Control | FO Room321 | Safe Navigation of Bipedal Robots Via Koopman Operator-Based Model Predictive Control | Kim, Jeonghwan; Han, Yunhai; Ravichandar, Harish; Ha, Sehoon | Sep. 29 | 11am - 12:30pm | Exhibit Hall B #3753 |
| 10:24am | Compliant Mechanisms for Bio-Inspired Locomotion | LT Room304/305 | Morphing MILR: Design and Control of a Cable-Driven Limbless Robot with Rolling Joints for Maneuvering in Complex Environments | Dortilus, Donoven; Wang, Tianyu; Tunnicliffe, Galen; Fernandez, Matthew; Goldman, Daniel | Sep.29 | 11am - 12:30pm | Exhibit Hall B #4277 |
| 2:43pm | Building Better Benchmarks for Robot Intelligence | LT Rooms302/303 | Constraint Learning in Multi-Agent Dynamic Games from Demonstrations of Local Nash Interactions | Zhang, Zhouyu; Chiu, Chih-Yuan; Chou, Glen | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #4891 |
| 2:48pm | Scaling Reinforcement Learning from Single Agents to Teams | LT Rooms409/410 | MO-Playground: Massively Parallelized Multi-Objective Reinforcement Learning for Robotics | Janwani, Neil; Novoseller, Ellen; Lawhern, Vernon; Tucker, Maegan | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #5022 |
| 2:52pm | New Designs for Steerable Continuum Robots | FO Room326 | Towards a Tendon-Driven Robotically Steerable Guidewire with a Retractable Distal Balloon | Barre, Christopher Cloud; Desai, Jaydev P | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #470 |
| 3:05pm | Designing Safe Physical Human-Robot Collaboration | LT Rooms403/404 | Multimodal Intervention Prediction for Proactive AR-Assisted Human-Robot Collaboration | Ajikumar, Akhil; Moghaddam, Mohsen | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #3410 |
| 3:16pm | Communication Protocols for Robot Teamwork | LT Rooms411/412 | Ask, Reason, Assist: Robot Collaboration Via Natural Language and Temporal Logic | Choe, Dan BW; Vinodh Sangeetha, Sundhar; Emanuel, Steven; Chiu, Chih-Yuan; Coogan, Samuel; Kousik, Shreyas | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #3253 |
| 3:38pm | Smarter Sensing for Autonomous Navigation | FO#3431 Room 319 | NavTrust: Benchmarking Trustworthiness for Embodied Navigation | Jiang, Huaide; Chaudhary, Yash; Wang, Yuping; Wang, Zehao; Sharma, Raghav; Mehta, Manan; Zhou, Yang; Sun, Lichao; Fan, Zhiwen; Tu, Zhengzhong; Li, Jiachen | Sep. 29 | 4:30pm - 6pm | Exhibit Hall B #3431 |
Tuesday Highlights
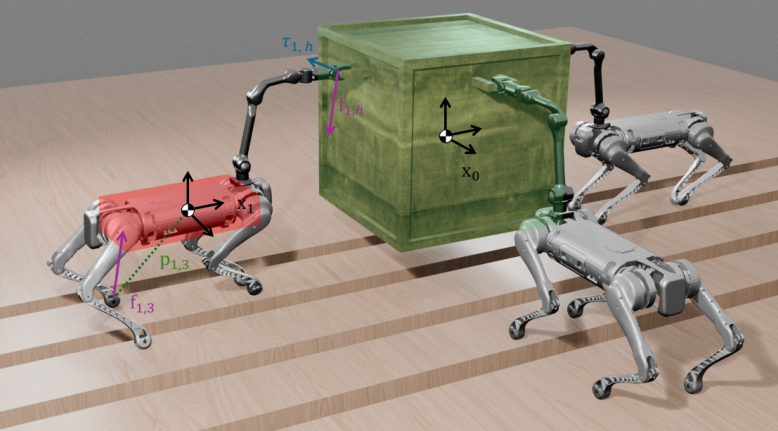
ACLM: ADMM-Based Distributed Model Predictive Control for Collaborative Loco-Manipulation
This study proposes an Alternating Direction Method of Multipliers (ADMM)-based distributed model predictive control framework for collaborative loco-manipulation with a team of quadruped robots with manipulators. By exploiting the payload-induced coupling structure, the global optimal control problem is decomposed into parallel individual-robot-level subproblems with consensus constraints.
MO-Playground: Massively Parallelized Multi-Objective Reinforcement Learning for Robotics
Multi-objective reinforcement learning (MORL) is a powerful tool to learn Pareto-optimal policy families across conflicting objectives. However, unlike traditional RL algo-rithms, existing MORL algorithms do not effectively leverage large-scale parallelization to concurrently simulate thousands of environments, resulting in vastly increased computation time. Ultimately, this has limited MORL’s application towards complex multi-objective robotics problems.
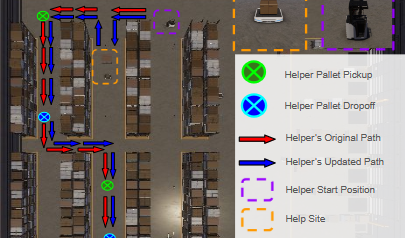
Ask, Reason, Assist: Robot Collaboration Via Natural Language and Temporal Logic
Increased robot deployment, such as in warehousing, has revealed a need for collaboration among heterogeneous robot teams to resolve unforeseen conflicts. To this end, we propose a peer-to-peer coordination protocol that enables robots to request and provide help without a central task allocator.
Wednesday September 30th Schedule at a Glance
| Time | Session Title & Location | Title | Authors | Poster Session Time & Location |
| 9:00am | The Mechanics of Legged and Musculoskeletal Motion | FO Room334 | A Robust Antenna Provides Tactile Feedback in a Multi-Legged Robot | Xu, Zhaochen James; He, Juntao; Aydin, Delfin; Taylor, Malaika; Wang, Tianyu; Lin, Jianfeng; Dyar, Wesley Nathanael; Goldman, Daniel | September 30 | 11am - 12:30pm | Exhibit Hall B #3305 |
| 9:01am | Keeping Robot Teams Resilient Under Adversity | FO Room325 | Failure-Aware Multi-Robot Coordination for Resilient and Adaptive Target Tracking | Li, Peihan; Liu, Jiazhen; Wu, Yuwei; Zhou, Lifeng | September 30 | 11am - 12:30pm | Exhibit Hall B #5013 |
| 9:16am | Immersive Interfaces for Robot Teleoperation | LT Rooms302/303 | AHEAD: Anticipatory Hand-Driven Teleoperation Via Human Intent Prediction | Kim, Seok Joon; Lee, Joonho; Spinola, Federica; Kwon, Taein; Moghaddam, Mohsen | September 30 | 11am - 12:30pm | Exhibit Hall B #3656 |
| 9:40am | Vehicle Navigation in Unstructured and Hazardous Settings | LT Rooms317/318 | Radiation-Aware Reinforcement Learning for Mobile Robot Navigation in Nuclear Environments Using World Models | Zebrowitz, Marc; Do, Youndo; Choi, Myeongjun; Zhang, Fan | September 30 | 11am - 12:30pm | Exhibit Hall B #4250 |
| 2:52pm | Robot Audition | FO Room406 | The Talking Robot: Distortion-Robust Acoustic Models for Robot-Robot Communication | Li, Hanlong; Kamalahasan, Karishma; Li, Jiahui; Nakadai, Kazuhiro; Kousik, Shreyas | September 30 | 11am - 12:30pm | Exhibit Hall B #3670 |
| 3:38pm | AI-Driven Advances in Task and Motion Planning | FO Room321 | Interleaved POMDP Planning for Multi-Object Search in Unknown Multi-Room Household Environments | Yang, Ruochu; Xia, Ziyi; Zhang, Huibo; Han, Yatong; Zhao, Yiming; Li, Yingke; Zhang, Fumin; Wardi, Yorai; Hou, Mengxue | September 30 | 11am - 12:30pm | Exhibit Hall B #4091 |
| 3:38pm | Localizing Multi-Robot Teams Without Central Control | FO Room325 | Asynchronous Distributed Trajectory Estimation of Multi-Robot Systems | Pooley, Adam; Hale, Matthew | September 30 | 11am - 12:30pm | Exhibit Hall B #3784 |
| 3:45pm | Estimating Physical Properties Through Diverse Senses | LT Rooms302/303 | Proprioceptive Safe Active Navigation and Exploration for Planetary Environments | Jiang, Matthew Yuting; Qian, Feifei; Liu, Shipeng | September 30 | 11am - 12:30pm | Exhibit Hall B #3725 |
Wednesday Highlights
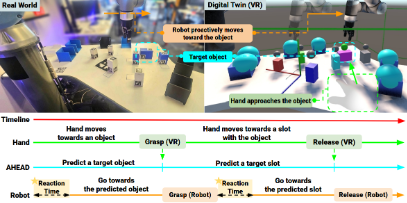
AHEAD: Anticipatory Hand-Driven Teleoperation via Human Intent Prediction
We present AHEAD, a real-time VR teleoperation system that anticipates operator intent to enable proactive, hand-driven control. In a digital twin, the operator performs pick-and-place naturally, using hand motion to convey high-level commands rather than a continuous robot trajectory.
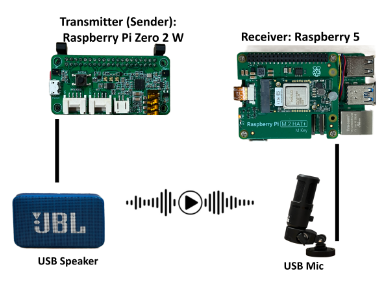
The Talking Robot: Distortion-Robust Acoustic Models for Robot-Robot Communication
We present Artoo, a learned acoustic communication system for robots that replaces hand-designed signal processing with end-to-end co-trained neural networks.
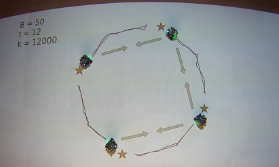
Asynchronous Distributed Trajectory Estimation of Multi-Robot Systems
We propose an asynchronous block coordinate descent algorithm for distributed trajectory estimation. We consider a team of agents that observes a team of robots and estimates the robots’ states over a sliding window.
GT@IROS - Workshops
State of the Art in Robotic Leg Prostheses: Where We Are and Where We Want to Be
3rd Edition
Full-day workshop October 1, 2026, Pittsburgh, PA, USA
Featuring
Kinsey Herrin
Human Interface Design Development and Engineering Lab
Georgia Tech
1st Workshop on
Neuromuscular Robotics
Full-day workshop October 1, 2026, Pittsburgh, PA, USA
Featuring
Prof. Gregory Sawicki
Physiology of Wearable Robotics Lab
Georgia Tech
Learning Deformable Cable Geometry for Collision-Free Planning of Construction Robots
Full-day workshop October 1, 2026, Pittsburgh, PA, USA
MORE INFO COMING SOON